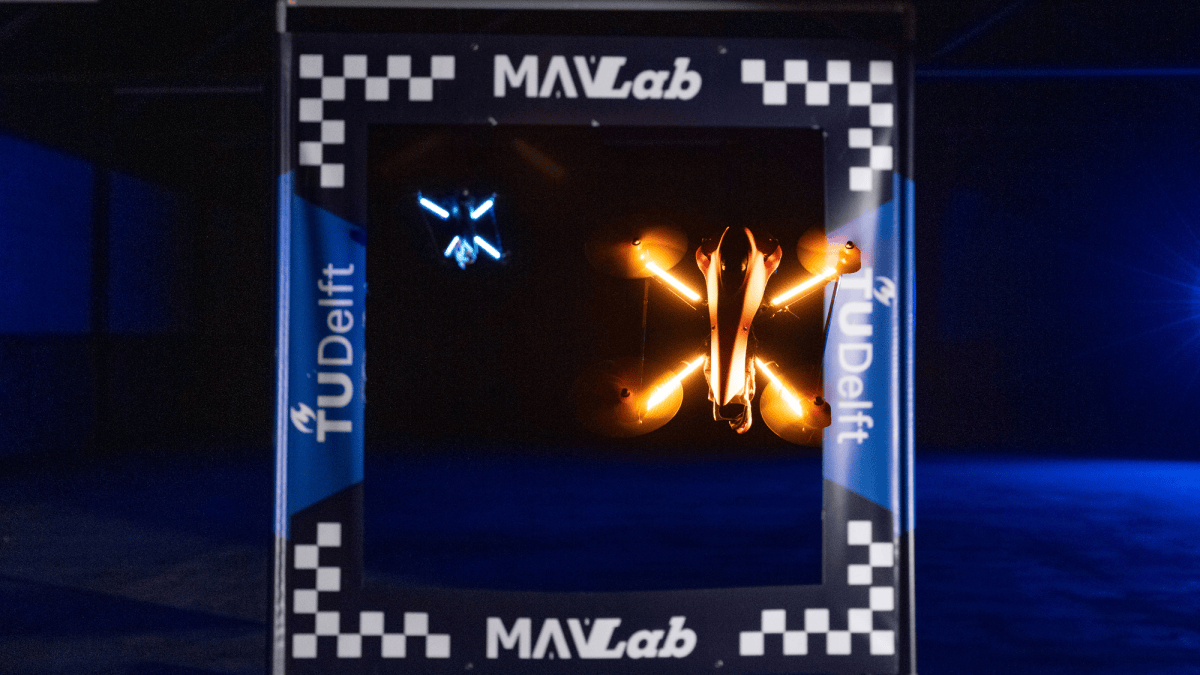
An autonomous racing drone developed at Delft University of Technology has defeated three human FPV world champions at the Abu Dhabi Autonomous Drone Racing Competition. The quadcopter relies on a single forward-facing camera and an onboard computer running a specialized neural network to fly complex courses at speeds exceeding 60 miles per hour without GPS.
MonoRace Outpaces Human Champions in Abu Dhabi
First-person-view drone racing demands lightning-fast reflexes from pilots who wear video goggles to steer remote-controlled aircraft through tight gates at extreme speeds. In November 2025, a competition in the United Arab Emirates pitted autonomous systems against human pilots during the Abu Dhabi Autonomous Drone Racing Competition. The autonomous quadcopter, designed by researchers at the Micro Air Vehicle Lab, bested every rival AI team and finished with a faster time than three human world-champion pilots.
The aircraft completed a two-lap course featuring 11 gates in just 16.56 seconds during a knockout tournament. During its aggressive runs, the machine reached speeds of up to 102 km/h, executing sharp turns, dives, and vertical loops without human intervention.
Delft Quadcopter Uses Onboard Hardware and Single Camera
Building an agile racing drone typically requires heavy sensors and offboard computing power. Earlier projects, such as the Swift AI model developed by the University of Zurich in 2022, relied on a camera to observe and locate gates and avoid obstacles in indoor environments with controlled lighting to beat human competitors.
By contrast, the Delft quadcopter — weighing 966 grams with a 30-by-28-by-10-centimeter frame — carries all its hardware onboard. The aircraft uses an NVIDIA Jetson Orin NX computer paired with a single forward-facing rolling-shutter camera and an inertial measurement unit. Because a lone camera produces blurry and deformed images at high velocities, the team engineered a method to combine visual gate detection with the drone’s motion data, allowing the system to fly without satellite positioning.
Operating a single camera at extreme velocities poses difficulties because the footage suffers from blur and distortion, leaving the AI minimal time to pinpoint the exact location of the drone. By blending optical data with the aircraft’s motion telemetry, we created a resilient mechanism that enables GPS-independent navigation around the circuit at high speeds.
Neural Networks and Reinforcement Learning Drive Flight Speed
The quadcopter’s speed stems from a streamlined neural network running directly on the flight controller at a frequency of 500 Hz. Instead of relying on conventional stabilization algorithms, the network generates direct commands for the four motors 500 times every second. Researchers trained the model using reinforcement learning in a simulation environment, where millions of trial-and-error runs taught the software to handle aggressive flight maneuvers from scratch.
This reinforcement learning process is run in a simulated environment because it requires many trials and errors, up to millions of times.
Guido de Croon, co-author and professor at Delft University of Technology, via Vnexpress
To prepare the software for unpredictable physical conditions, the team introduced variations in battery voltage, weight, aerodynamic drag, sensor noise, and propeller wear during training. When rapid acceleration occasionally pushed the inertial measurement unit beyond its limits or electrical interference distorted camera images, the system rejected faulty data and relied on its motion model to predict correct acceleration values.
Physical AI Beyond the Laboratory
The success of MonoRace highlights broader shifts in physical artificial intelligence, demonstrating that complex robotic control does not require massive computing setups. Aerospace engineers note that extreme sports serve as a rigorous proving ground for technology designed to operate reliably in the physical world.
Instead of giving the robot increasingly powerful sensors and computers, we wanted to find out how much intelligence we could extract from very limited resources. Drone racing provided an extreme environment in which to test these ideas outside the laboratory. It pushed us to develop AI that was not only fast but also robust, and able to adapt when external reference measurements were unavailable.
Christophe De Wagter, aerospace engineer at Delft University of Technology, via Popsci and Vnexpress
Despite the win, the system retains practical limitations. The aircraft requires a previously mapped course and cannot yet detect or dodge other moving drones — a factor that caused a collision during multidrone heats in Abu Dhabi. Researchers detailed the technical architecture of their approach in Science Robotics, suggesting the framework could eventually guide autonomous aircraft operating where GPS and external positioning infrastructure are absent.