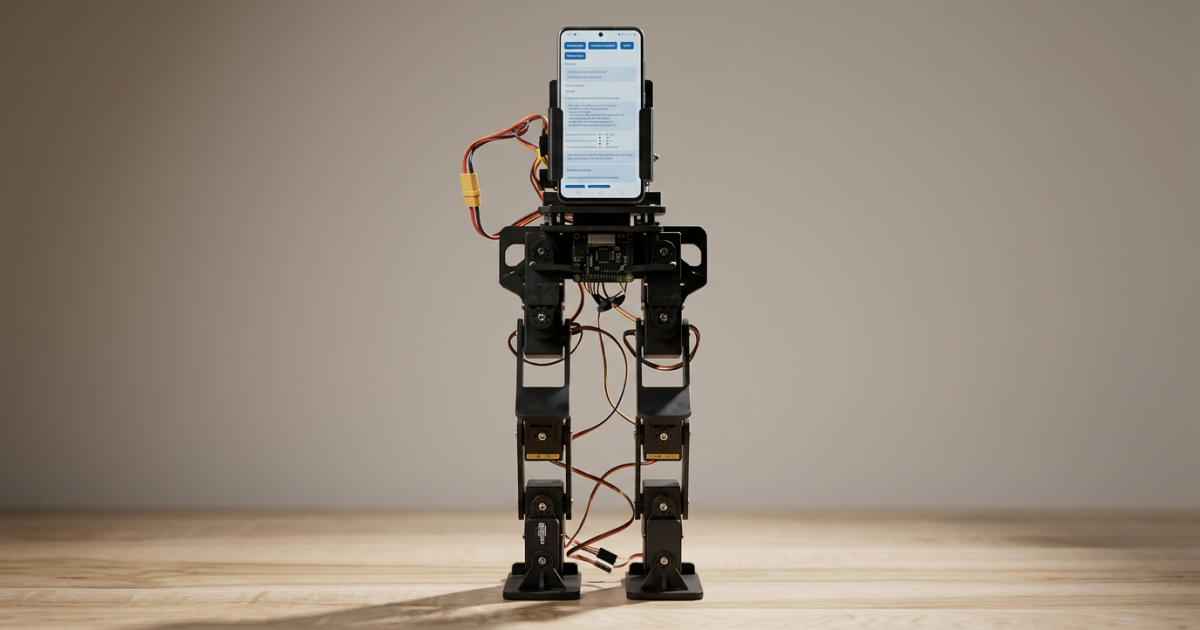
Researchers at UCLA built PhoneBot for roughly $400 in extra hardware, mounting an old Android smartphone above the hips of a 19-inch bipedal robot so it can walk, track people, and recover from falls using repurposed consumer electronics.
UCLA Engineers Build Cheap Bipedal Robot Using Old Mobile Devices
That old mobile device gathering dust in a junk drawer could soon find a second life turning smartphones into small robot companions. Engineers at the Robotics and Mechanisms Laboratory (RoMeLa) at the University of California, Los Angeles, have introduced a bipedal platform called PhoneBot that strips away the expensive sensors and dedicated vision computers typically required for small research humanoids. Described in a preprint paper titled PhoneBot: A Low-Cost Open Humanoid Robot Platform Reusing Smartphones
shared on arXiv, the project demonstrates how consumer hardware can slash the cost and complexity of building robots.
Instead of custom hardware, the 48-centimeter-tall machine uses an Android smartphone for camera-based vision, motion sensing, and movement-control computation. The phone rests in a mount above the hips, serving as both the torso and the primary intelligence unit while a small onboard computer relays commands to the motors over Wi-Fi.
Because the connection runs wirelessly rather than through hardwiring, swapping out different handsets requires no alterations to the internal wiring before you add the phone. The phone’s camera handles object detection and human tracking, while its built-in inertial measurement unit acts like an inner ear to sense tilt and motion.
Engineers Keep Build Costs Low With Servo Motors
The entire physical build costs about 400 US dollars, excluding the price of the mobile device itself. Other small research humanoids listed in the project’s preprint paper range between $3,500 and $13,800.

Weighing 1.8 kilograms including its battery and phone, the robot relies on 13 low-cost servo motors driven by DYNAMIXEL XL430-W250-T servos: three per hip, one per knee, two per ankle, and one additional motor dedicated to swiveling the torso. That central rotation lets the camera follow a person across a room without the robot needing to reposition its feet.
Researchers Test Four Different Handsets on the Robot
To verify hardware versatility, the research team tested four distinct handsets ranging from a 2017 Honor 9 to modern entry-level devices. The test group included a 2017 Honor 9, a Moto G 2025, a Samsung Galaxy A16 5G, and a Moto G 2024. All four devices successfully powered core functions such as motion control, sensor data evaluation, and image processing.
What if the cheapest humanoid computer is the phone you stopped using?@UCLA 's PhoneBot is a 48cm, 13-DoF biped with an estimated $400 hardware cost (phone excluded). The phone runs a 50Hz walking policy, camera perception and IMU sensing. A small SBC forwards its Wi-Fi… pic.twitter.com/5hfpblPLVr
Camera-based mapping and localization failed to run on the 2017 Honor 9 because Google services were unavailable on that specific device. Speech interaction also relies on external hardware for now, with speech recognition and language processing running on a nearby laptop.
Software Training Teaches PhoneBot to Walk and Stand
Before taking its first physical steps, PhoneBot practiced walking in a simulation environment using reinforcement learning, earning points for maintaining pace and staying upright while losing points for dragging its feet. The simulation accounted for the limited strength of the motors. Training the walking controller was a difficult technical challenge before researchers finalized the gait loop.
Initial training runs in simulation left one leg carrying an uneven load due to gait asymmetries. Researchers resolved this by applying sagittal mirroring, a technique that duplicates training samples with left and right movements swapped.
Following the training transfer, physical demonstrations showed the robot walking on level ground, tracking people with its camera, and pushing itself back up independently from a face-down position.