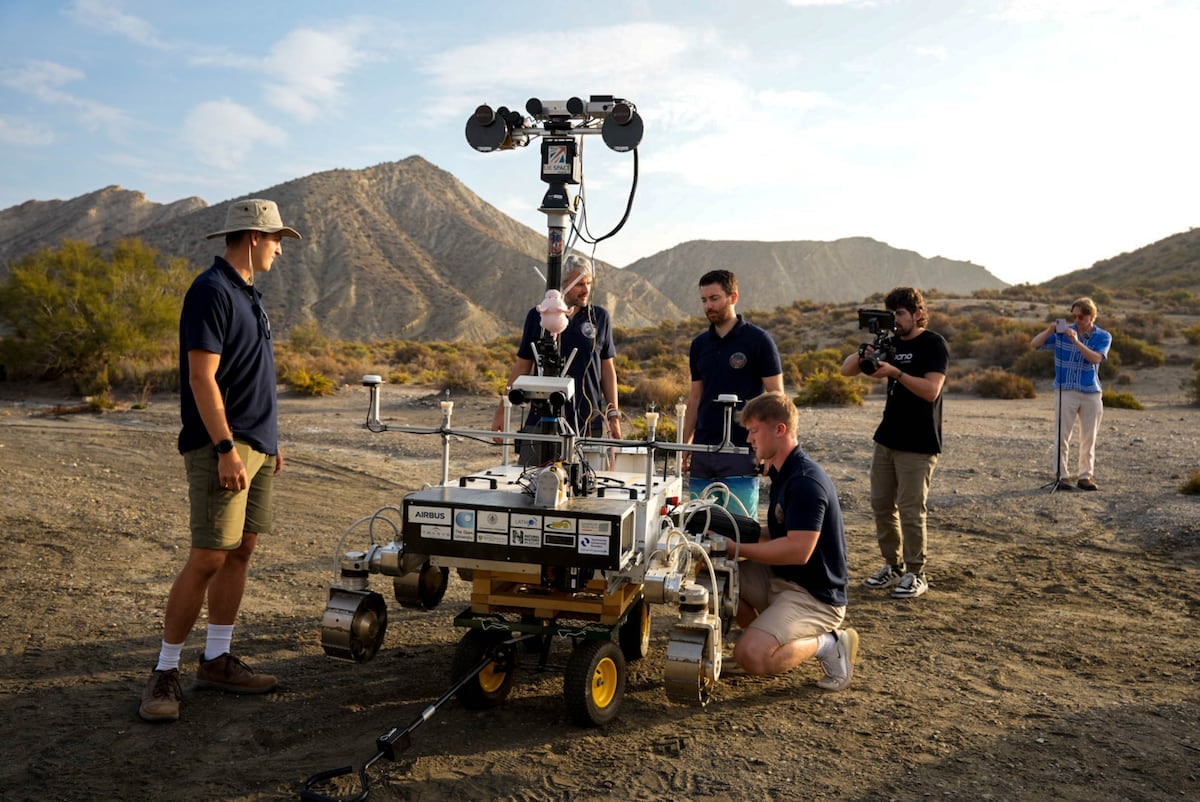
Engineers and scientists have wrapped up a three-week testing campaign in Spain’s Tabernas desert using a six-wheeled Mars rover prototype named Charlie, training remote operators in Turin, Italy, to prepare for the European Space Agency’s ExoMars Rosalind Franklin mission launching in 2028.
The Tabernas desert in Almería, Spain, offered a landscape of fine dusty soil, rocky scree, and salt-encrusted ground that mirrored the conditions expected on the red planet. Across the Las Lomillas terrain, a field team supported operational simulations concluded on 1 October 2026. The campaign brought together the European Space Agency, Airbus, and various European industrial and research partners to evaluate technologies for the upcoming ExoMars mission.
Simulating Martian Latency and Remote Operations From Italy
While the six-wheeled prototype crossed the Spanish scrub, approximately 60 engineers at the Rover Operations Control Centre in Turin, Italy, managed its movements via satellite links. Because communication between Earth and Mars involves a significant time delay of several minutes—scaling to around 20 minutes at the speed of light—real-time manual steering remains impossible during actual planetary operations. The control team prepared daily activity schedules each morning and transmitted them to the desert, where field engineers uploaded the instructions to Charlie.
This setup tested how well the vehicle could steer itself when Earth-based operators cannot respond immediately.
Why the Tabernas Desert Matches Martian Geology
The current campaign tested stereoscopic localization cameras, obstacle avoidance software, and route-planning algorithms designed to help the flight rover travel about 100 metres during a single Martian sol without human intervention.
Engineering the Rosalind Franklin Flight Vehicle for 2028
Although Charlie will remain on Earth as a ground-based engineering demonstrator, it shares the wheels, mast, base, and chassis mobility of the flight vehicle that will make the journey. The ExoMars program itself began more than a decade ago. Following setbacks that included the Schiaparelli module crash landing at about 540 kilometers per hour, engineers utilized telemetry data to refine the design for the second phase of the program.
European industry completed and qualified the landing and related systems to preserve the target of a 2028 launch and a 2030 arrival at Oxia Planum.
Drilling Beneath Oxia Planum to Search for Ancient Biosignatures
Once the Rosalind Franklin rover touches down on the Martian surface in 2030, its primary objective will be searching for signs of past or present life in clay deposits formed when liquid water existed on the planet. The vehicle carries a dedicated subsurface drill capable of extracting core samples down to about two meters deep.
“Below the surface, whatever is there is better protected from events such as radiation, and the rover will carry a laboratory capable of analyzing samples in situ to look for traces of life.”
Vincent Schaeffer, via El Pais
The extracted samples will be sent directly to an internal laboratory on the rover, allowing researchers to evaluate whether Mars once maintained conditions suitable for life before organic molecules near the ground were destroyed by cosmic radiation.