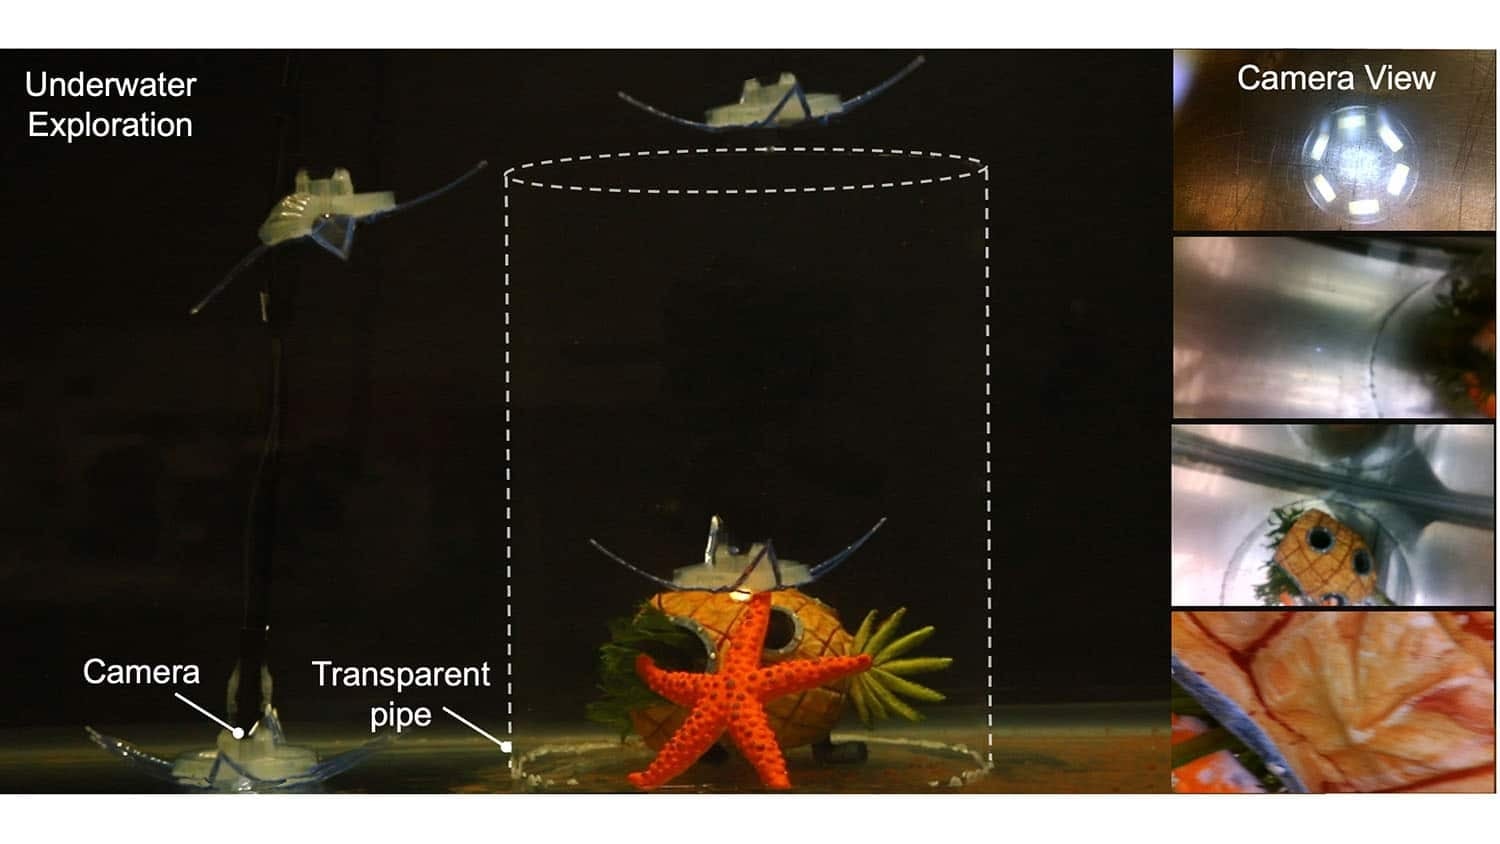
Researchers at North Carolina State University have developed an aquatic soft robot inspired by feather stars, achieving three-dimensional movement through the water using just two pneumatic actuators and a monostable wing structure that relies on mechanical intelligence to reduce control complexity.
Marine Invertebrate Design Cuts Actuator Requirements From Six to Two
Conventional aquatic systems designed for full three-dimensional movement typically require at least six actuators to navigate up and down, move forward and backward, and rotate on an axis. Engineering teams at North Carolina State University bypassed this mechanical complexity by looking to marine invertebrates known as feather stars, which coordinate their slender limbs to hover and travel in any direction.
Two years ago, Hurricane Helene brought historic wind speeds and flooding to western North Carolina.Since then, NC State’s North Carolina Institute for Climate Studies has been lending a helping hand to recovery efforts with climate data. Read: https://t.co/FPdF3vjcqL pic.twitter.com/5xDiWbRry2
The feather star, in effect, offers a blueprint for getting complex behavior out of simple control. The North Carolina State team translated that idea into a physical platform. Instead of copying each individual arm precisely, the machine adopts the core concept—pliant limbs powered by very few actuators—allowing a handful of moving components to generate a propulsion cycle that mimics the creature’s natural motion.
The resulting soft robotic swimmer features four elastic wings arranged around a central disk that houses two pneumatic inputs. These wings are monostable, meaning they bend under force but snap back to their baseline position when the actuators disengage. By distributing motion through the physical structure rather than adding independent motors for every direction, the design leverages a concept the team calls mechanical intelligence. This describes active systems whose actions are directed mostly by their physical form and environmental feedback, cutting down on the degree of control needed from human operators or computers.
One exciting aspect of this work is that it demonstrates how we can create robotic devices with an incredible range of motion using a minimum number of actuators, by taking advantage of intelligent design techniques.
Jie Yin, corresponding author and professor of mechanical and aerospace engineering at North Carolina State University
Jellyfish, Fish, and Rotor Modes Power Three-Dimensional Mobility
Coordinating the two actuators in different sequences allows the swimmer to switch between three distinct movement modes: jellyfish-like pulsation, fishlike propulsion, and rotor-like reorientation. Activating both actuators simultaneously causes all four wings to snap downward, while shutting them off returns the wings upward. Rapidly cycling this action makes the robot rise in the water column, while slowing the flap allows it to maintain position in what researchers term jellyfish mode.

Horizontal travel relies on a different control scheme. Activating a single actuator causes one wing to flutter like a tailfin, pushing the body in the opposite direction in what the team calls fish mode. Rotor mode fires the two actuators alternatively, enabling the robot to rotate on its axis so the team can steer it in any direction.
Fluid Dynamics Testing and Future Wireless Development Plans
Testing data published in the open-access journal Science Advances documented a maximum swimming speed of 1.64 body lengths per second alongside a peak rotation speed of 90 degrees per second. Flow analysis and fluid simulations uncovered distinct vortex patterns driving the thrust and rotation in each mode.
The team built this on a previously manta ray-inspired swimmer. While that prior machine achieved high forward speeds, it lacked the three-dimensional maneuverability of the new design, according to Haitao Qing, the paper’s first author and a postdoctoral researcher at UC Berkeley. The author says a fully wireless version is already next in line. The mechanical engineers are also looking for partners to explore applications.