
Sensory reweighting and proximal muscle reorganization drive postural control after a unilateral lower limb amputation, according to a study published in Scientific Reports.
The study examined seven people with a unilateral transtibial amputation. They included 6 males and 1 female.
The group had an average age of 57.00 plus or minus 8.96 years. Their average height was 179.20 plus or minus 5.07 cm.
Average weight reached 76.94 plus or minus 9.42 kg. Trials involved participants standing on platforms.
Researchers applied two complementary analytical approaches. Transfer function analysis estimated model parameters.
Non-negative matrix factorization of surface electromyography extracted muscle synergies. Testing measured anthropometric segment heights for each participant.
Three-dimensional positions of head, upper body shoulder, and lower body hip segments were tracked during each trial using the Captury system. A Delsys EMG device was hardware-triggered alongside it.
During each pseudorandom binary sequence trial, the stimulus was repeated three times. Transfer functions were computed separately for each cycle by calculating the discrete Fourier transform of stimulus and response signals sampled at 100 Hz.
Rotation trials used a fundamental frequency of 0.0501 Hz. A cycle length of 1997 samples at 100 Hz determined this value, yielding 50 frequency components as integer multiples of this fundamental frequency.
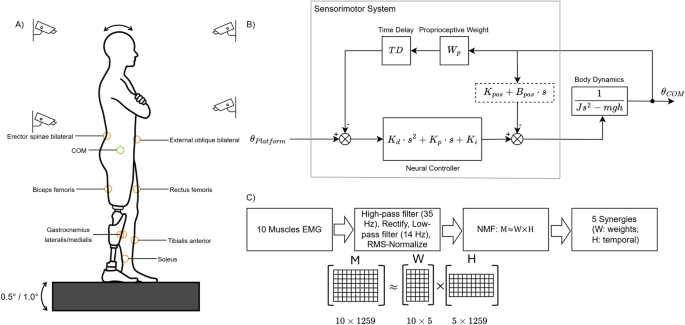
Model parameter optimization used starting values set at 950 for the proportional gain parameter. Derivative gain was set at 250.
Sensory weighting started at 0.8, and effective time delays started at 0.15. Lower bounds were established at 500 for proportional gain and 100 for derivative gain.
Lower bounds for sensory weighting and effective time delays sat at 0. Upper bounds reached 1500 for proportional gain and 500 for derivative gain.
Upper bounds reached 1 for sensory weighting and 0.40 for effective time delays. Effective time delays represented the time from stimulus to a response in seconds.
Sensory weighting quantified the relative contribution of proprioceptive feedback to postural control across a range from zero to one. Surface electromyography data processing involved full-wave rectification to obtain absolute activation amplitude.
Low-pass filtering followed at 14 Hz via a 5th-order Butterworth zero-phase filter to extract the activation envelope. Non-negative matrix factorization was implemented using the module from scikit-learn version 1.7.1.
The module ran via the R package reticulate 1.44.1 inside a conda environment running Python version 3.10.18. Statistical analyses managed data exclusions.
Control participant 15 was omitted from analysis. Control participant 1 was restricted solely to the postural control model.
Control participants 21 through 22 were used exclusively for electromyography analysis owing to missing kinematic data. Contrasts of vision and amplitude were pooled across all remaining factor combinations and adjusted using Sidak corrections for the total count.
All statistical evaluations were executed in R version 4.5.2. Statistical significance was established at an alpha level of 0.05.